
Greek Pilot - Collaborative robotics towards an early wildfire detection concept

Sustainability Aspects: Collaborative Robotics for Search & Rescue
Targeted Vertical: Life-saving environmental preservation
Partners:
- Institute of Communication & Computer Systems (ICCS): Use Case leader, Developer and Integrator
- National Center for Scientific Research ‘Demokritos’ (NCSRD) / ORGANISMOS TILEPIKOINONION TIS ELLADOS (ΟΤΕ): Testbed Providers
- ORGANISMOS TILEPIKOINONION TIS ELLADOS (ΟΤΕ): Telecom Operator
- INFOLYSiS: Developer & Integrator
- Elliniki Omada Diasosis Attikis (HRTA): End User
This use case focuses jointly on collaborative robotics search and rescue and early wildfire detection concepts. The exact trial site’s location will be determined during the preparation phase and the trials plan.
6G-VERSUS Greek Pilot – Collaborative robotics towards an early wildfire detection concept
Motivation and challenges:
Wildfires present significant challenges for search and rescue (SAR) operations because of their rapid evolution, hazardous conditions, limited visibility, difficult terrain, and the possibility of incomplete or degraded communication coverage. First responders may be exposed to smoke, extreme heat, rapidly changing fire fronts and areas that are difficult or unsafe to access. At the same time, effective SAR increasingly depends on timely situational awareness, early fire detection, victim localisation, continuous exchange of HD/UHD video and telemetry, and reliable coordination between aerial, ground and control-room assets. Traditional approaches often rely heavily on direct human intervention and can be constrained by limited accessibility, incomplete operational information and communication gaps in remote or obstructed areas.
The Greek use case addresses these challenges by combining B5G/6G technologies and exposed 3GPP network APIs with AI-enabled video analytics, a mission UAV (mUAV), a robotic dog/UGV, a dedicated relay UAV (rUAV), edge/Extreme-Edge processing and control-room functions. The objective is to reduce human exposure while improving early smoke/fire detection, victim localisation and prioritisation, collaborative aerial-ground search, service continuity in obstructed areas, and operational decision support. In particular, the relay UAV extends coverage by bridging PC5 sidelink connectivity from the robotic dog to Uu connectivity towards the gNB, while Energy Efficiency as a Service (EEaaS) supports monitoring and energy-aware operation of the overall solution.
Solutions/Trial scenarios to address the challenges
The trial scenarios demonstrate the use case innovations through an integrated operational storyline. In a remote forest or peri-urban forest area under wildfire risk, a 5G-connected HD/4K camera using CPE/Wi-Fi 6 provides a continuous video stream to AI functions for early smoke and fire detection (step 1 in Figure). A B5G/6G-enabled system with exposed 3GPP APIs supports network/service awareness and the provision of network information to application and AI functions. When a potential event is detected, alerts are sent to the control room, where a web-based interface provides live visualisation of the deployed cameras, access to previous events and service-performance awareness for the relevant stakeholders (2).
Once fire detection is confirmed, a victim-localisation workflow combines network-based location information from different cells with AI/analytics to estimate and prioritise possible casualty locations within the hazardous area (3). A mission UAV (mUAV) is dispatched to high-priority areas to provide aerial imagery and telemetry, while the robotic dog is deployed into dense vegetation, smoke-affected zones or other areas that may be difficult or unsafe for first responders to access directly (4). Live video streams from the mUAV and the robotic dog are processed by edge/Extreme-Edge AI functions for detection, tracking and event annotation, producing a continuously updated operational picture for the control room and first responders (5).
Where the robotic dog experiences insufficient or obstructed direct connectivity, a dedicated relay UAV (rUAV) provides coverage extension: the robotic dog establishes a PC5 sidelink to the rUAV, while the rUAV maintains Uu connectivity towards the gNB, effectively forming a PC5-Uu bridge and preserving video, telemetry and control/service continuity (6). The robotic dog can then approach the victim area, support victim localisation and communication, transport essential supplies where appropriate, and provide information to first responders, who receive the integrated operational picture for safer and better-informed SAR intervention (7).
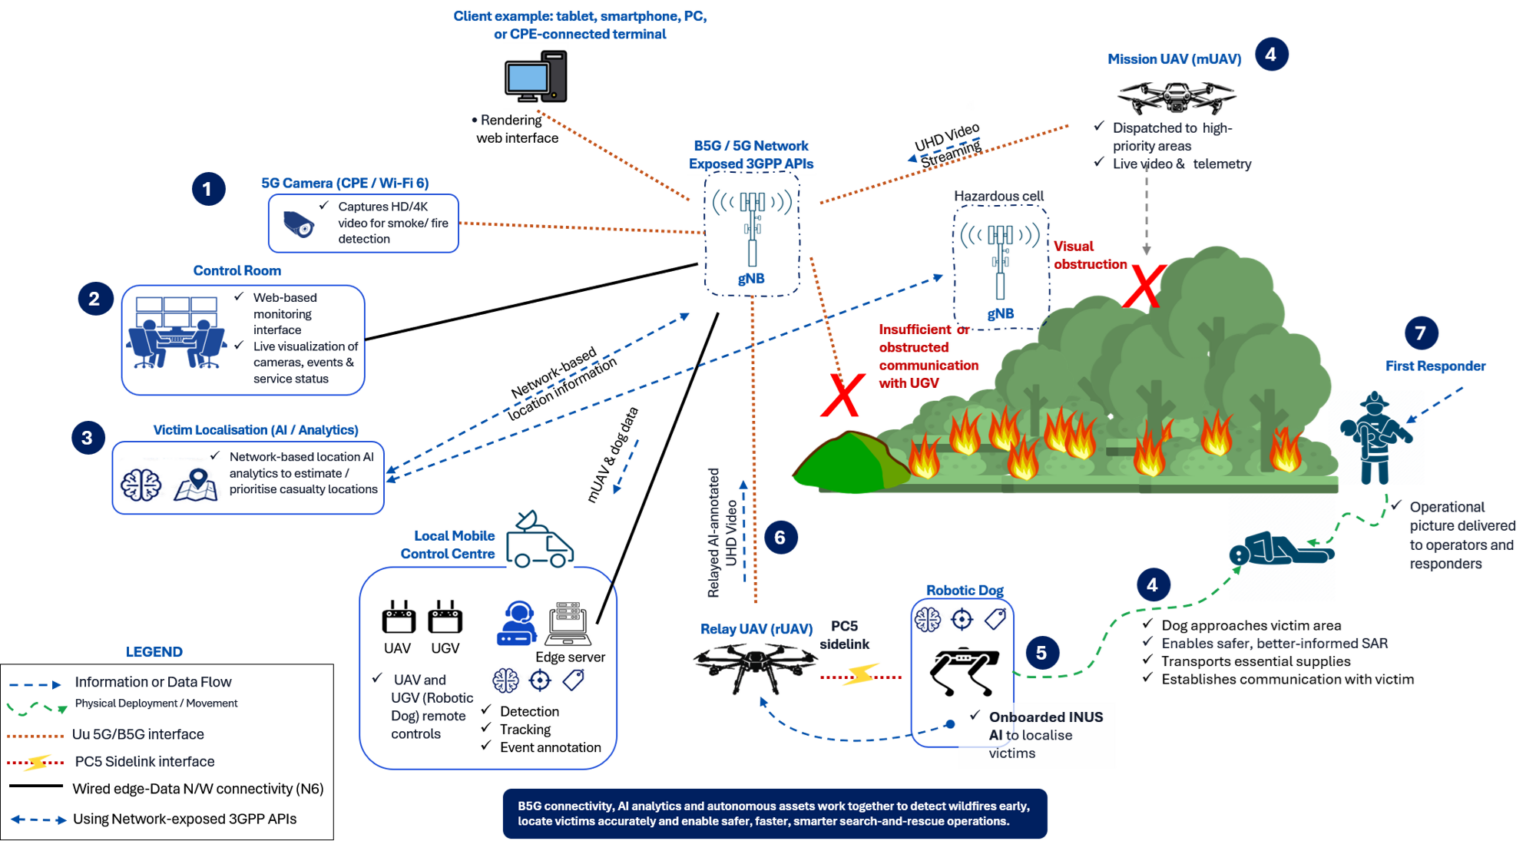
The main 6G-VERSUS application components (app triplet) are summarised in Table 1.
Table 1: 6G-VERSUS application components for Greek use case
| V-apps | (1) Control-room / Wildfire-CC functionality for alerts, live visualisation of camera feeds, access to previous events, mission monitoring and service-performance awareness; (2) orchestration and monitoring of the available robotic assets (mUAV, rUAV and robotic dog) towards SAR missions and prioritised areas; (3) delivery of the integrated operational picture to operators and first responders; (4) interaction with sustainability/EEaaS information to support energy-aware operation of the vertical service. |
|---|---|
| AI-apps | (1) early smoke/fire detection from fixed-camera and UAV video streams; (2) victim/casualty localisation and prioritisation by combining network-based location information with AI/analytics; (3) detection, tracking and event annotation from mUAV and robotic-dog video; (4) edge/Extreme-Edge AI processing to reduce reaction time and enhance situational awareness; (5) decision-support functions for mission planning and the allocation of robotic resources according to operational needs. |
| N-Apps | (1) QoS/service-aware network support for the application flows, including video, telemetry and control; (2) Coverage Extension through the relay UAV, using PC5 sidelink between the robotic dog and rUAV and Uu connectivity from the rUAV towards the gNB; (3) exposure and use of standard network APIs and network/location information to support victim-localisation and AI functions; (4) EEaaS for fine-grained energy-efficiency monitoring and energy-aware policies, exposing relevant energy information towards the application layer. |
Updated against the current SNS JU Vertical Cartography entry for the 6G-VERSUS Greek use case and the latest Greek pilot/trial configuration.
As sustainability is of vital importance in 6G-VERSUS, the main sustainability challenges are summarized together with the expected outcomes of this use case in Table 2.
Table 2: Main sustainability challenges and expected outcomes for Greek use case.
| Main Sustainability Challenges |
|---|
| 1) Environmental sustainability: Minimization of the ecological footprint of the proposed solution, by adopting EEaaS approaches |
| 2) Societal sustainability: a) Personal health and protection from harm; b) Protect quality of life in remote communities |
| Expected Outcomes |
| 1) Ultra reliable and low latency communication between all collaborative entities by offering a plethora of communication technologies that can be utilized in an ad-hoc manner. Low latency communication will be met by the utilization of MEC capabilities into several entities of the use case: on the drone, close to RRU/BBU, close to a group of RRUs/BBUs, in the cloud. |
| 2) Utilization of high accuracy AI-based algorithms with high processing power needs by capitalizing on the MEC capabilities. Dynamic resource and service allocation approach and dynamic decision-making algorithms will be adopted, which realize service migration to appropriate MEC locations on demand. |
| 3) EEaaS will increase energy efficiency, while energy related decision-making procedures can be executed on the application side (e.g. low energy consumption on regular periods (green path), maximize operational efficiency during incidents). |
Acronyms:
- UAV: Unmanned Aerial Vehicle
- SaR: Search and Rescue
- B5G: Beyond 5th Generation of mobile network technologies
- 4K: Ultra High Definition video with 4K resolution
- MEC: Multi-access Edge Computing, a network architecture concept enabling cloud computing at the edge of the network
- EEaaS: Energy Efficiency as a Service
- API: Application Programming Interface as a set of protocols for building and integrating application software
- RRU: Remote Radio Unit for radio transmission and reception
- BBU: Base-band Unit for processing base-band signals in mobile networks